UT Austin Villa
RoboCup@Home DSPL Team
The UT Austin Villa@Home team competes in the RoboCup@Home Domestic Standard Platform League using the Toyota Human Support Robot. The league aims to develop domestic service robot technology and evaluates performance in a set of benchmark tests in a realistic home environment.
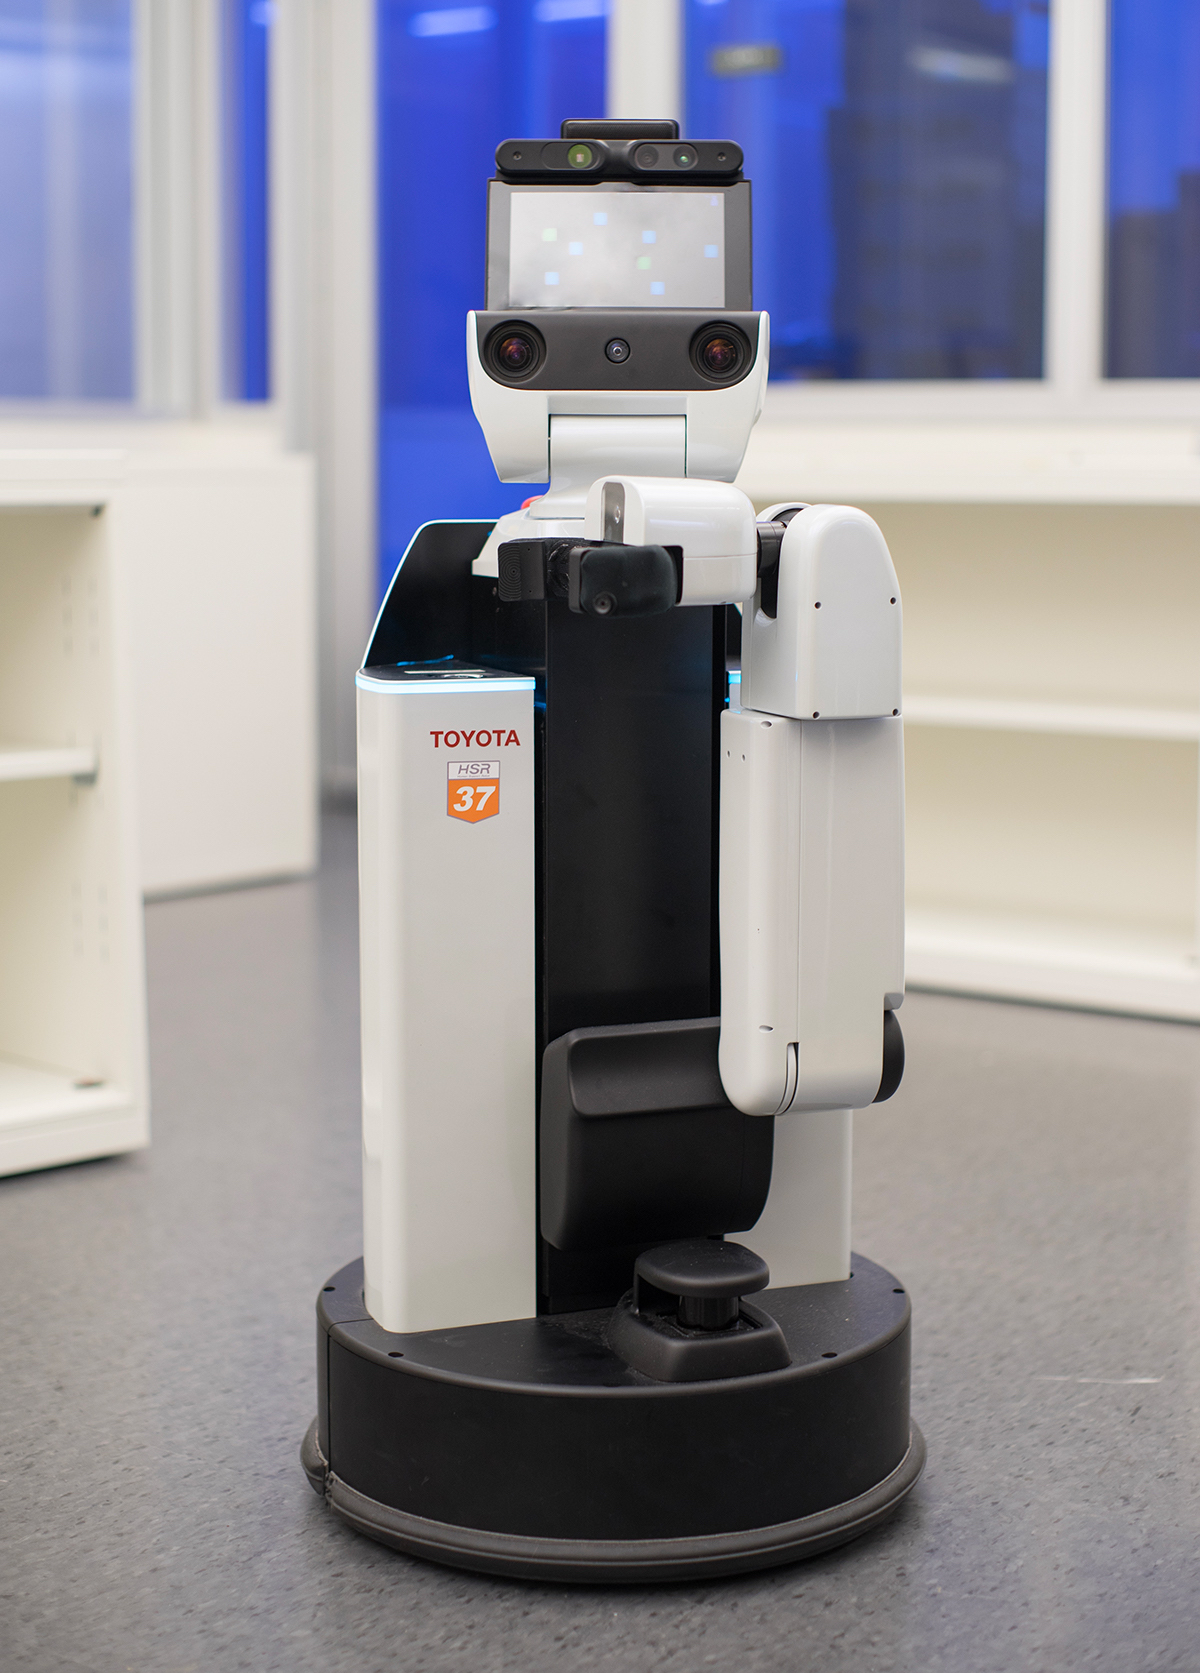
The Human Support Robot (HSR).
The team is a collaboration between PIs and students in the Computer Science, Mechanical Engineering and Aerospace Engineering departments at the University of Texas at Austin.
Over the past three years, we have constructed a framework intended to act as a comprehensive domestic service robot system, spanning multiple robot platforms. As instantiated in RoboCup@Home, our goal is to develop a single system which competes in every round, rather than a suite of software tailored to each round. In the realization of this goal, we have ported our RoboCup@Home code back to the Building-Wide Intelligence (BWI) infrastructure. As instantiated in BWI, the goal of this project is to deploy a service robot in our computer science department which responds to the day-to-day needs of the building's occupants, and is considered a part of the fabric of our department.
Relevant publications
- Papers produced by the UT Austin Villa@Home RoboCup@Home team
- Rishi Shah, Yuqian Jiang, Haresh Karnan, Gilberto Briscoe-Martinez, Dominick Mulder, Ryan Gupta, Rachel Schlossman, Marika Murphy, Justin Hart, Luis Sentis, and Peter Stone. Solving Service Robot Tasks: UT Austin Villa@Home 2019 Team Report. In AAAI Fall Symposium on Artificial Intelligence and Human-Robot Interaction for Service Robots in Human Environments (AI-HRI 2019), November 2019.
- Yuqian Jiang, Nick Walker, Justin Hart, and Peter Stone. Open-World Reasoning for Service Robots. In Proceedings of the 29th International Conference on Automated Planning and Scheduling (ICAPS 2019), July 2019.
- Justin W. Hart, Rishi Shah, Sean Kirmani, Nick Walker, Kathryn Baldauf, Nathan
John, and Peter Stone. PRISM: Pose registration for integrated semantic mapping. In Proceedings of the 2018 IEEE/RSJ International Conference on Intelligent
Robots and Systems (IROS), Madrid, Spain, October 2018.
- Justin W. Hart, Harel Yedidsion, Yuqian Jiang, Nick Walker, Rishi Shah, Jesse Thomason, Aishwarya Padmakumar, Rolando Fernandez, Jivko Sinapov, Raymond Mooney, and Peter Stone. Interaction and Autonomy in RoboCup@Home and Building-Wide Intelligence. In Proceedings of the AAAI Fall Symposium on Interactive Learning in Artificial Intelligence for Human-Robot Interaction, Washington, DC, USA, October 2018.
- Yuqian Jiang, Nick Walker, Minkyu Kim, Nicolas Brissonneau, Daniel S. Brown,
Justin W. Hart, Scott Niekum, Luis Sentis, and Peter Stone. Laair: A layered architecture for autonomous interactive robots. In Proceedings of the AAAI Fall
Symposium on Reasoning and Learning in Real-World Systems for Long-Term Autonomy, Washington, DC, USA, October 2018.
- UT Austin Villa's RoboCup-related
papers (from Prof. Stone's group).
- Relevant publications from the Building-Wide Intelligence
(BWI) project.
Software
During our participation in the RoboCup@Home SPL, we are
committed to continuing our strong tradition of contributing open
source code to the community.
- Our BWI code
repository provides an open source suite of ROS packages, fully
integrated into an architecture for service robots that operate in
dynamic and unstructured human-inhabited environments. It has been
built on top of the Robot Operating System (ROS) middleware
framework. As of the 2019/2020 season, we have ported our system developed for RoboCup@Home into the publicly available packages for BWI, and recommend going through this repository for the highest-quality versions of these packages.
- The bwi_common package contains our robot-independent software. The linked
branch has the robot architecture used in both RoboCup@Home and BWI.
- The knowledge_representation package contains our knowledge representation software used in both RoboCup@Home and BWI.
- The object_cloud package contains our software for query-able point cloud of objects used in both RoboCup@Home and BWI.
- Our software release for paper Open-World Reasoning for Service Robots provides a suite of packages for knowledge representation and planning as an approach to the General Purpose Service Robot test.
Team Members
- PIs
- Graduate Students
- Undergraduate Students
Additionally, we will be recruiting students from the Freshman Research Initiative Autonomous Intelligent Robotics stream.
Previous participation in RoboCup
Photos/videos
Getting ready for test, RoboCup 2019 in Sydney, Australia
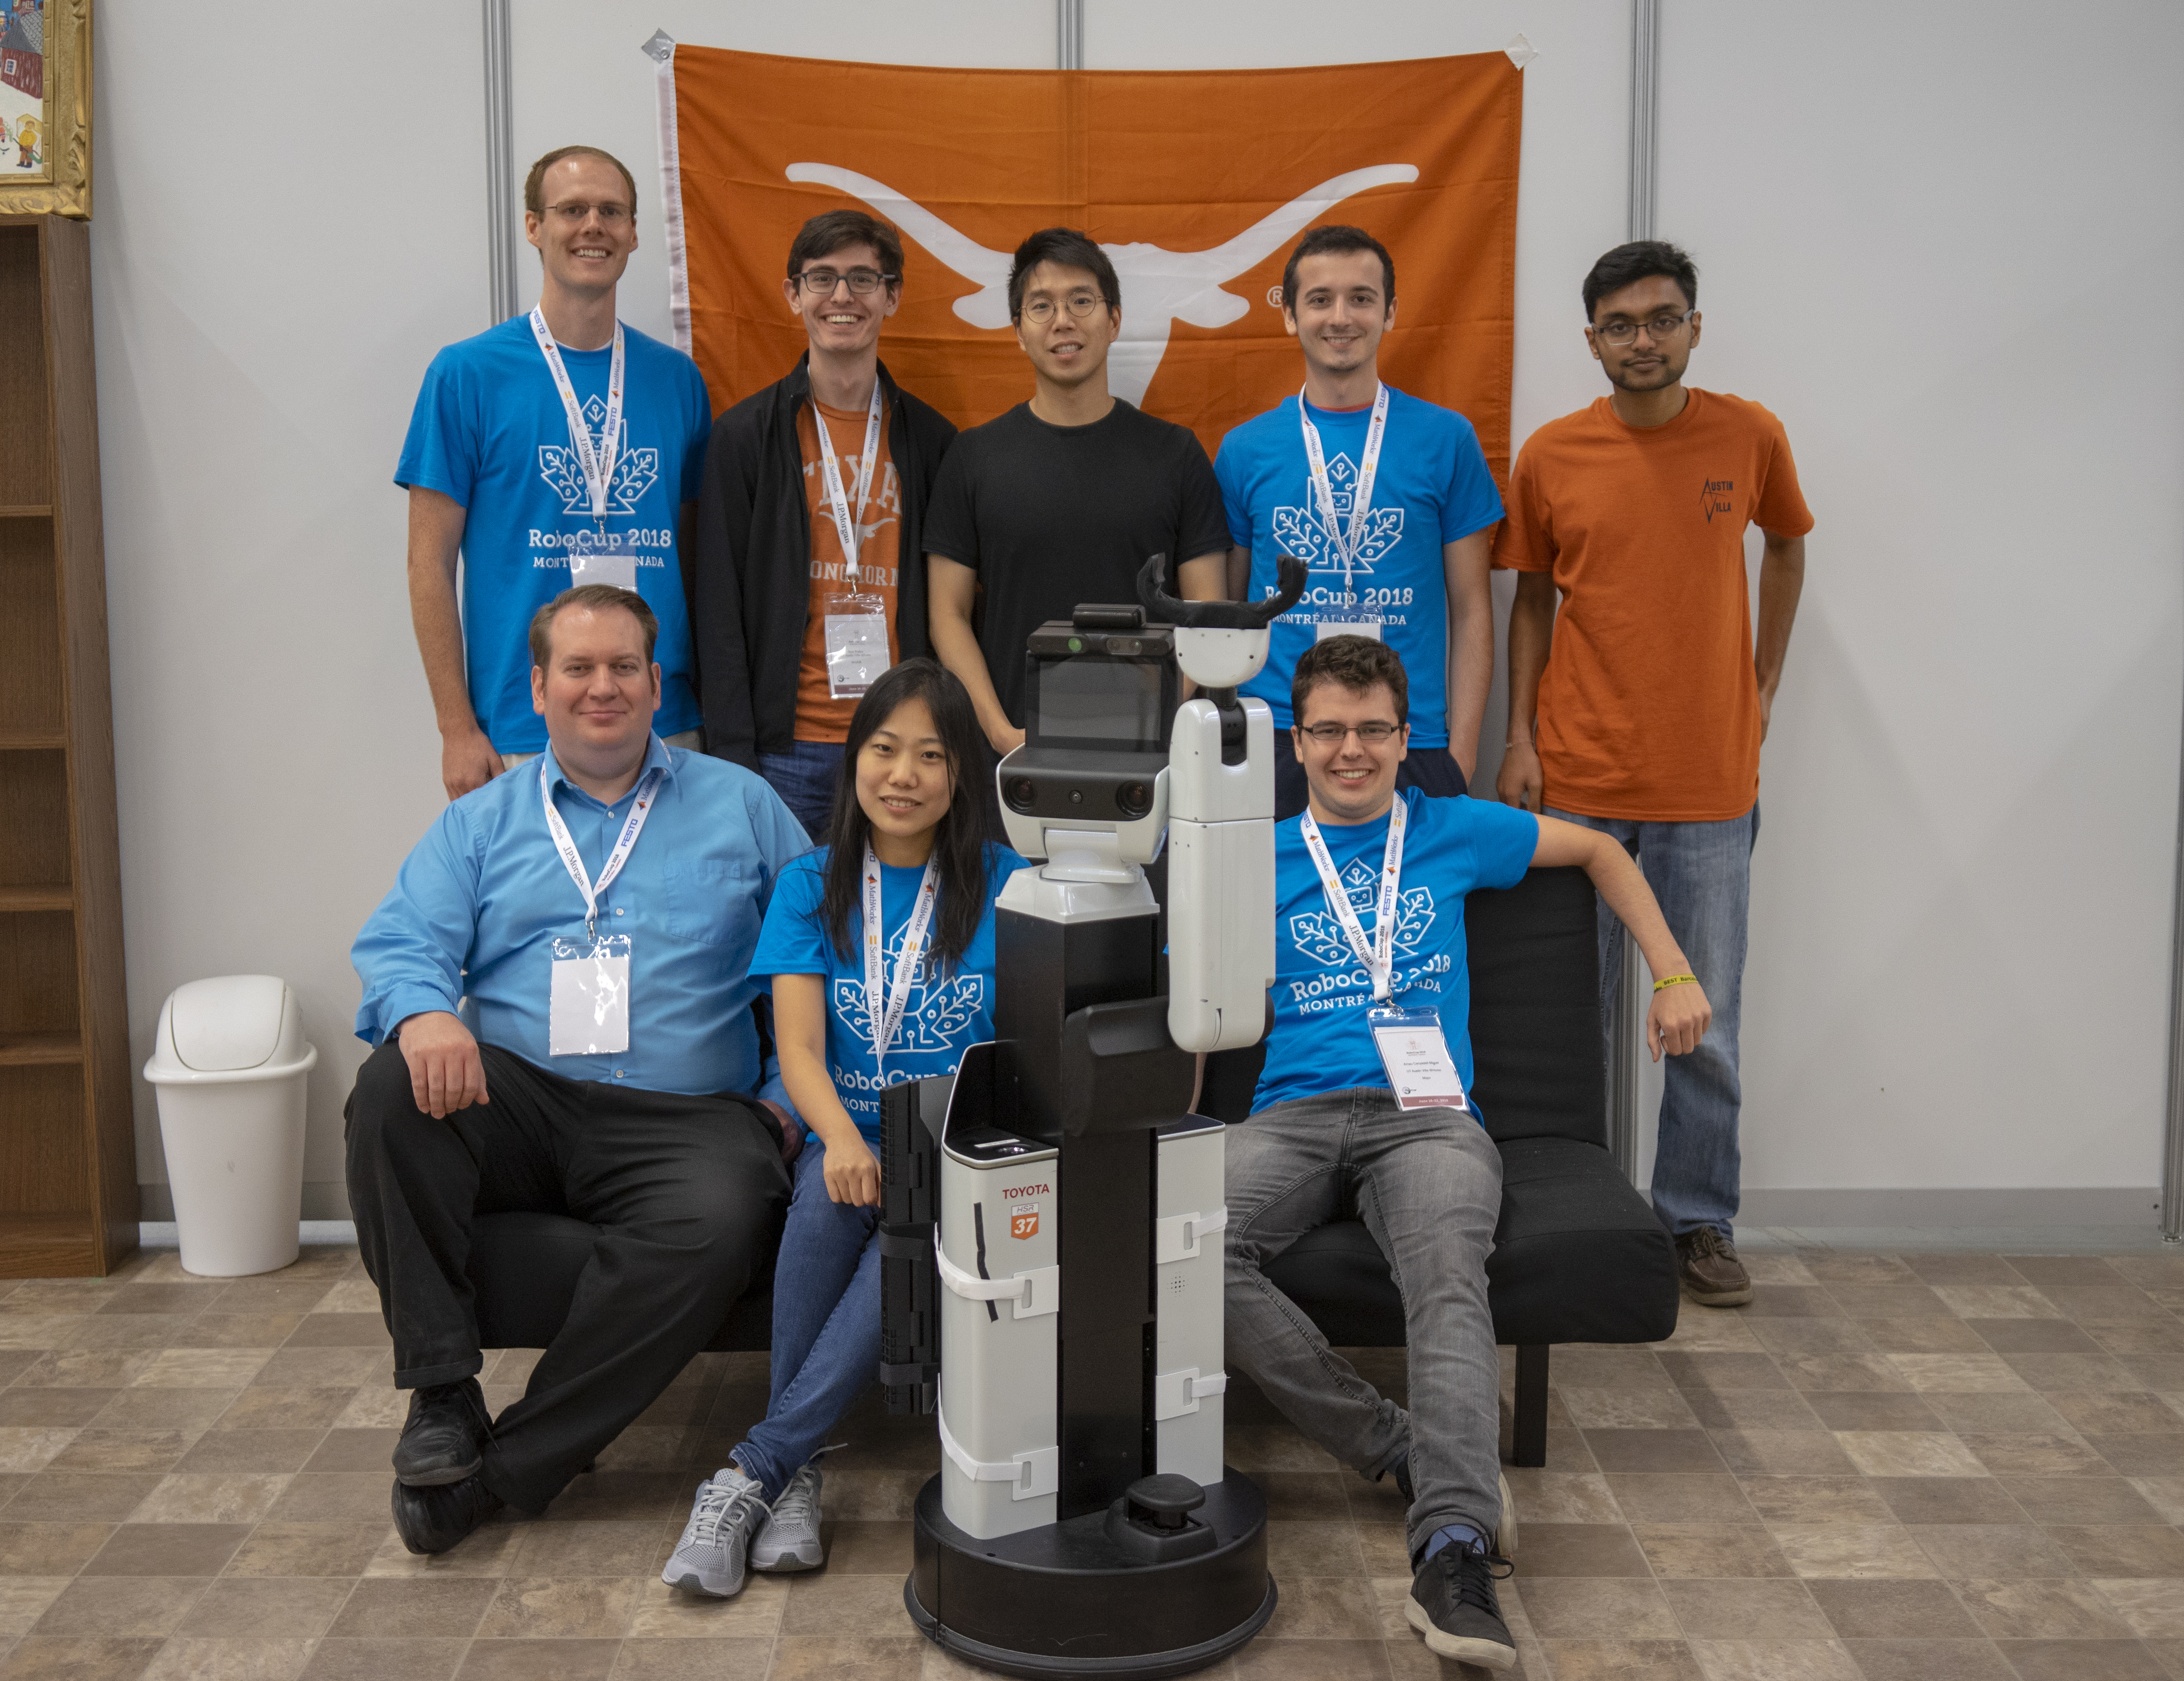
Posing in the arena, RoboCup 2018 in Montreal, Quebec, Canada
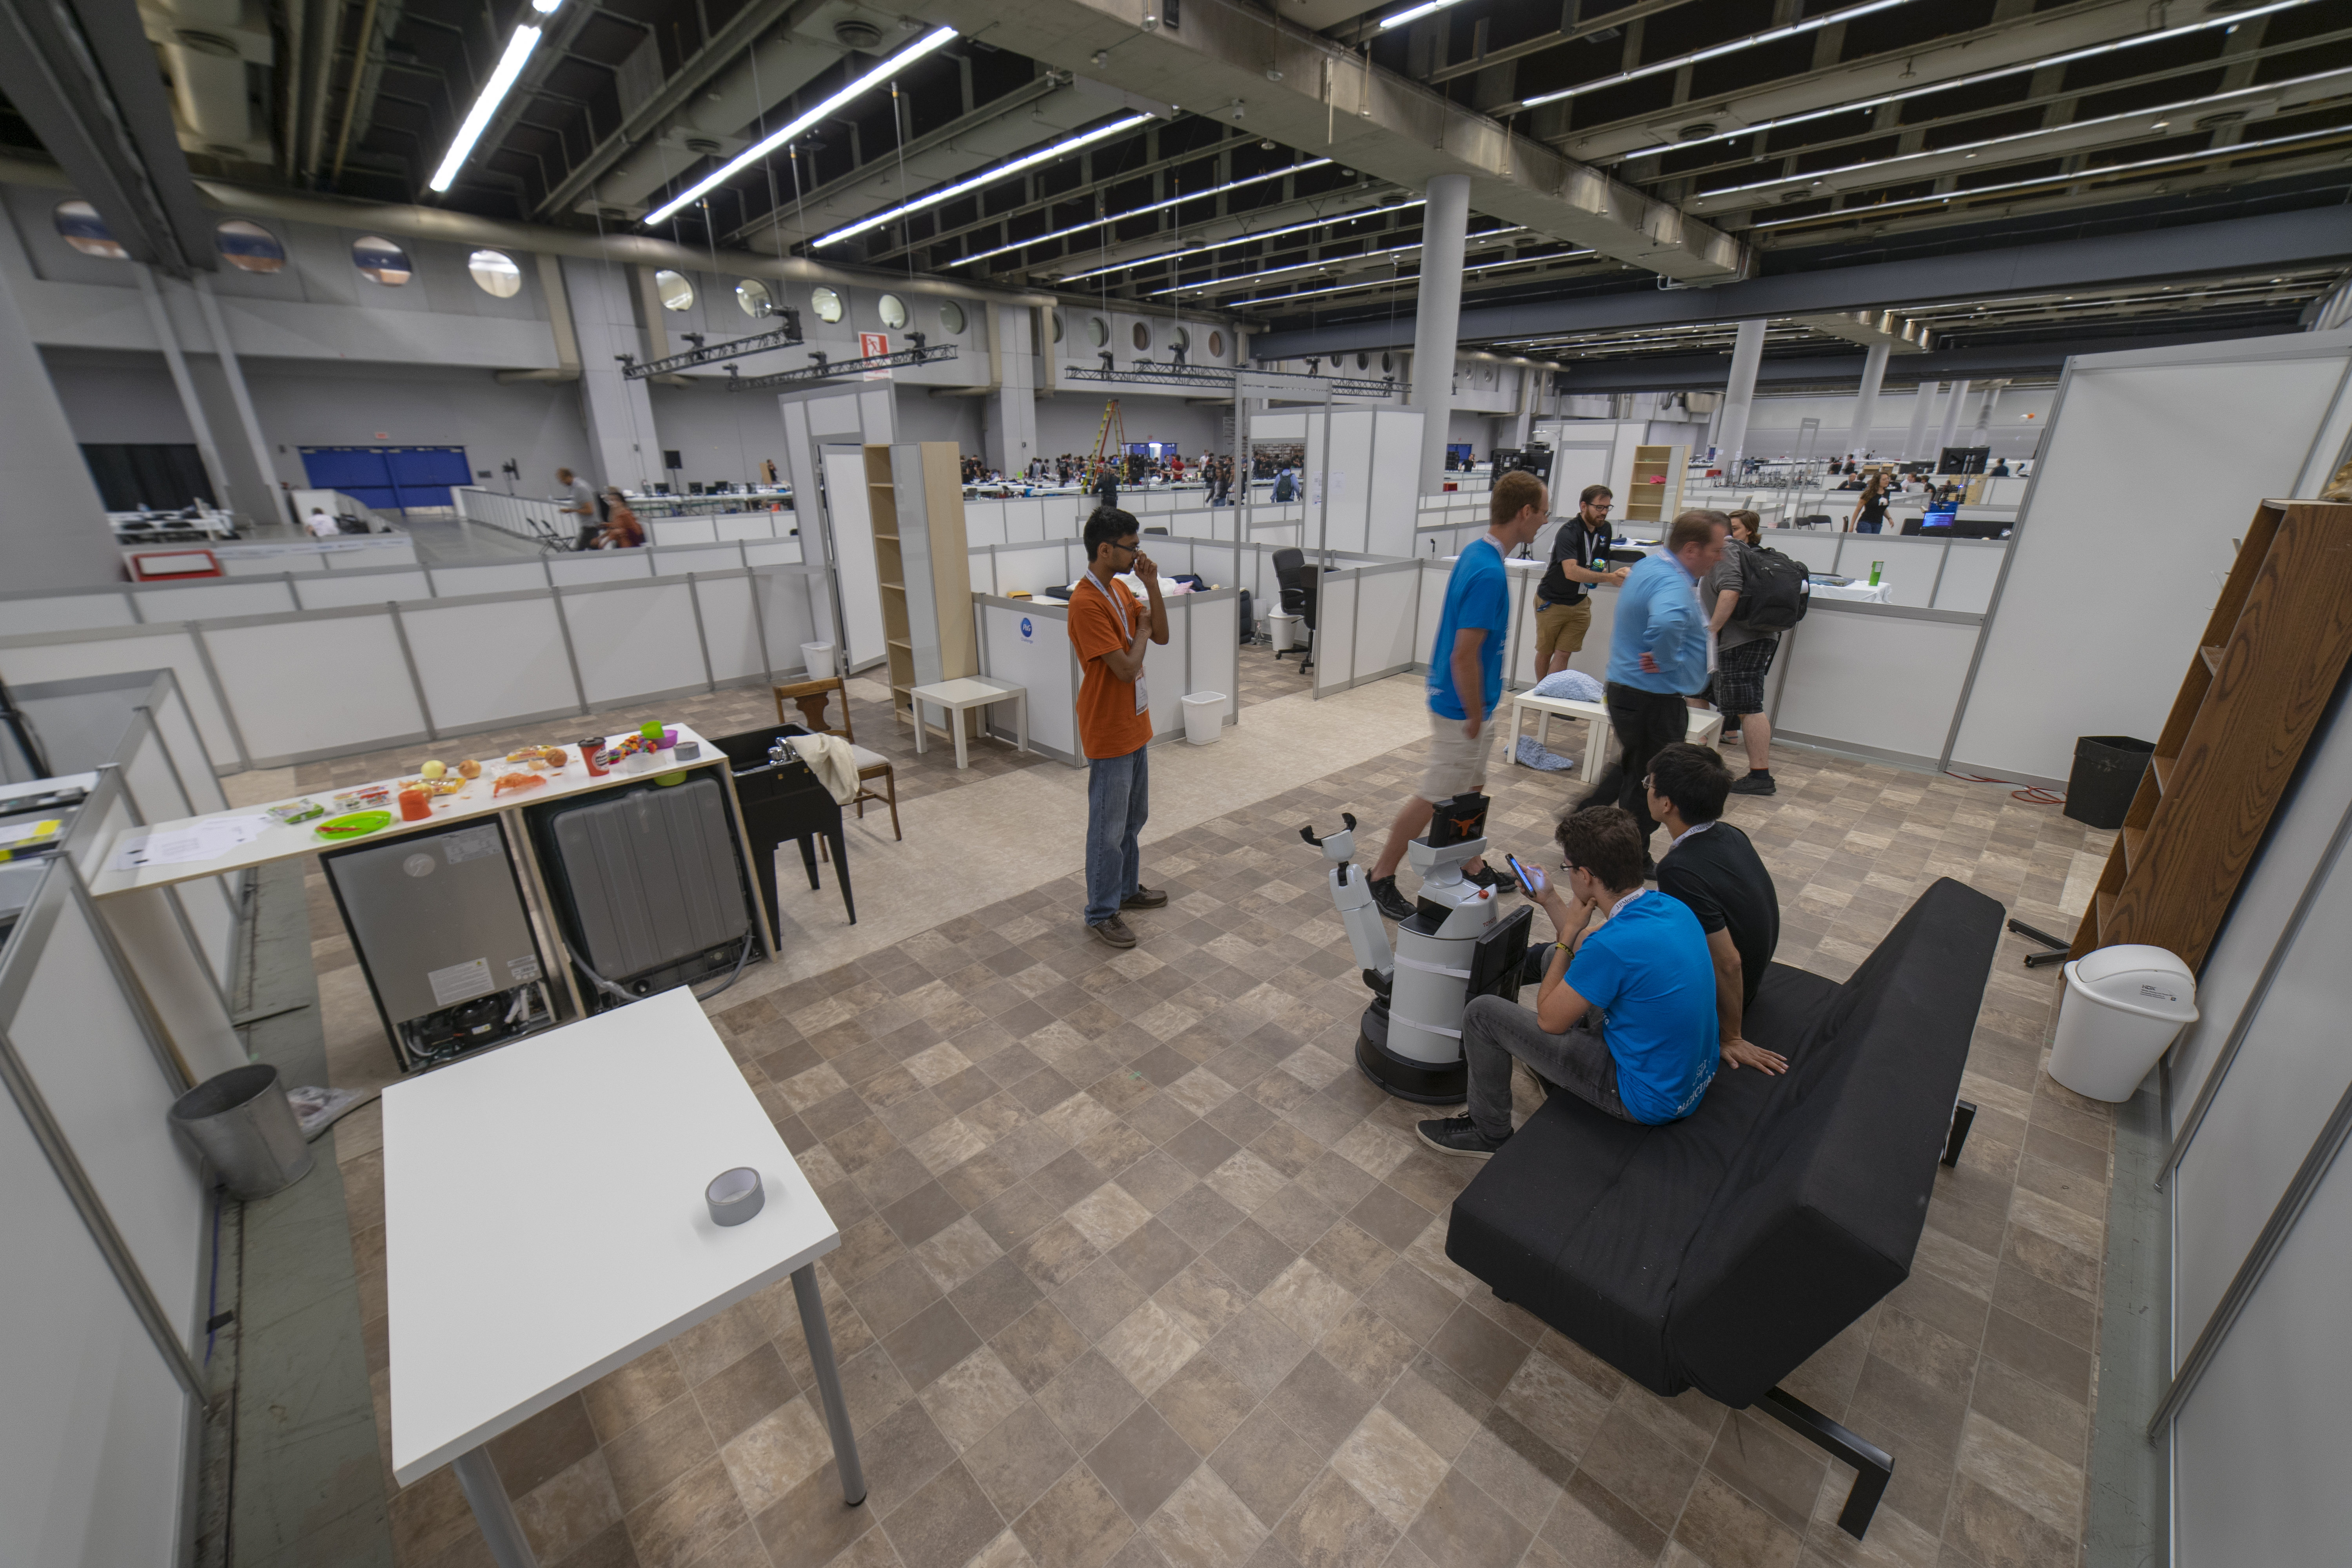
Working on robot setup, RoboCup 2018 in Montreal, Quebec, Canada
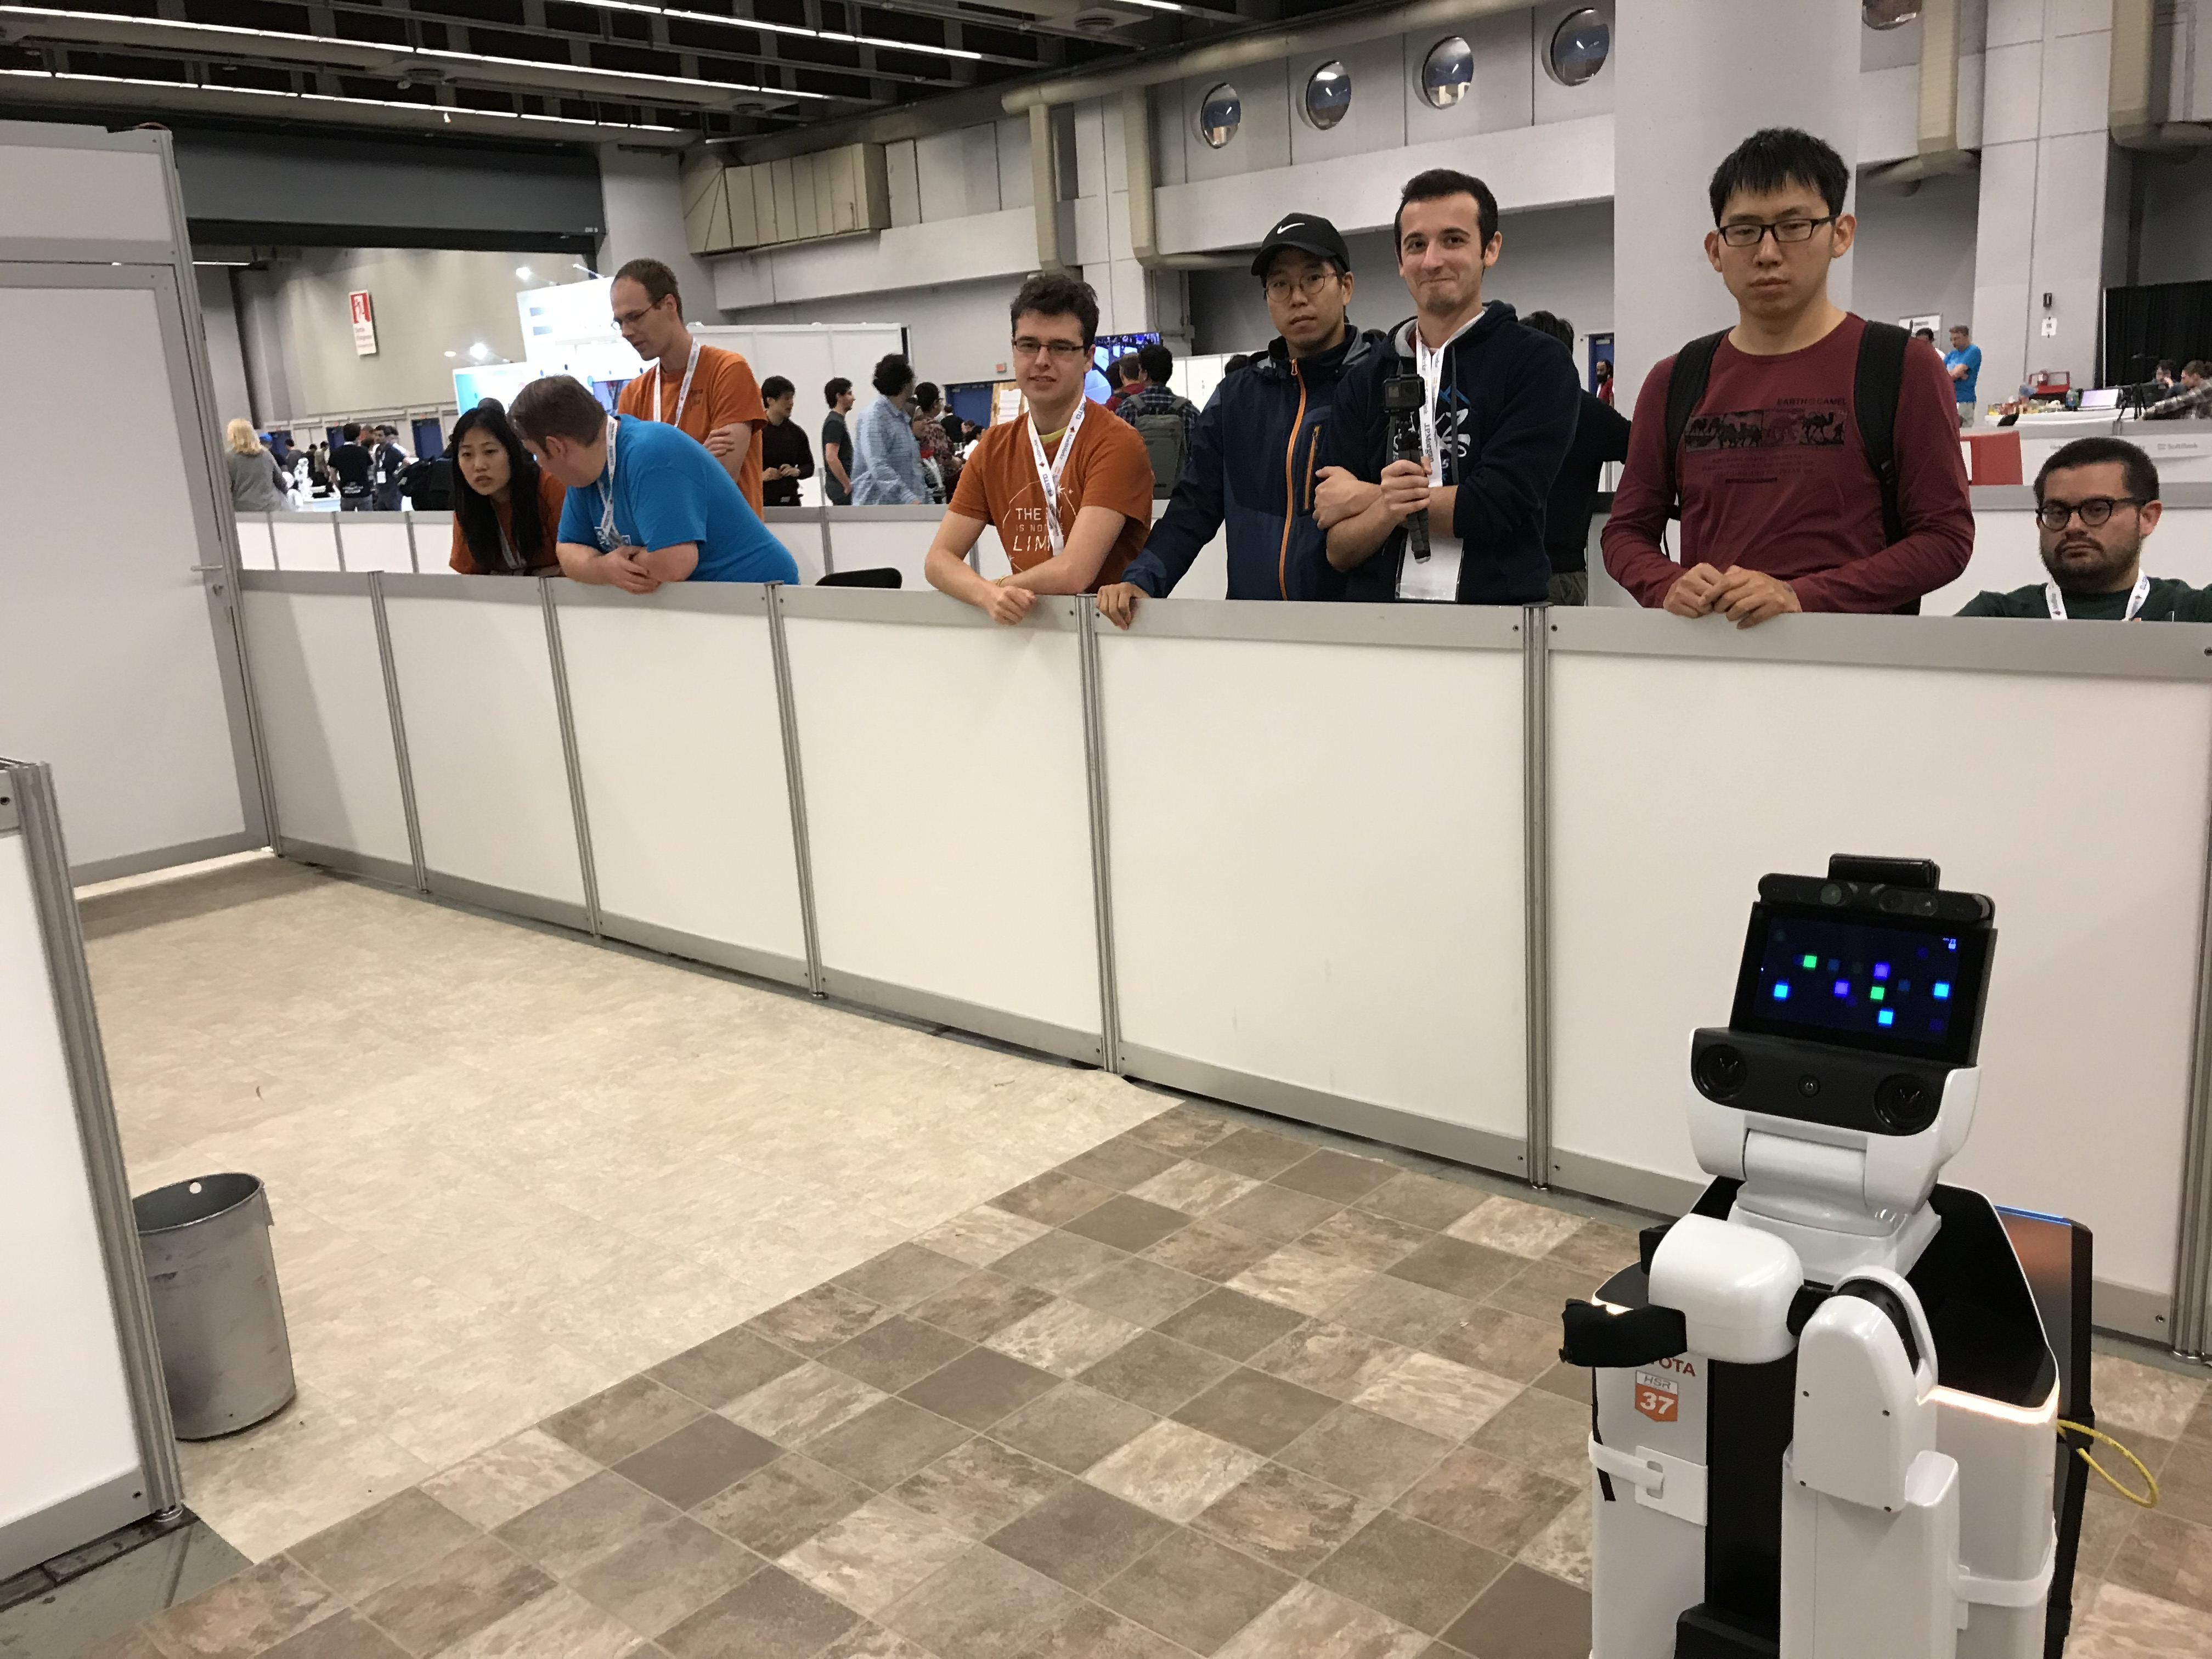
Excited to watch our GPSR run, RoboCup 2018 in Montreal, Quebec, Canada
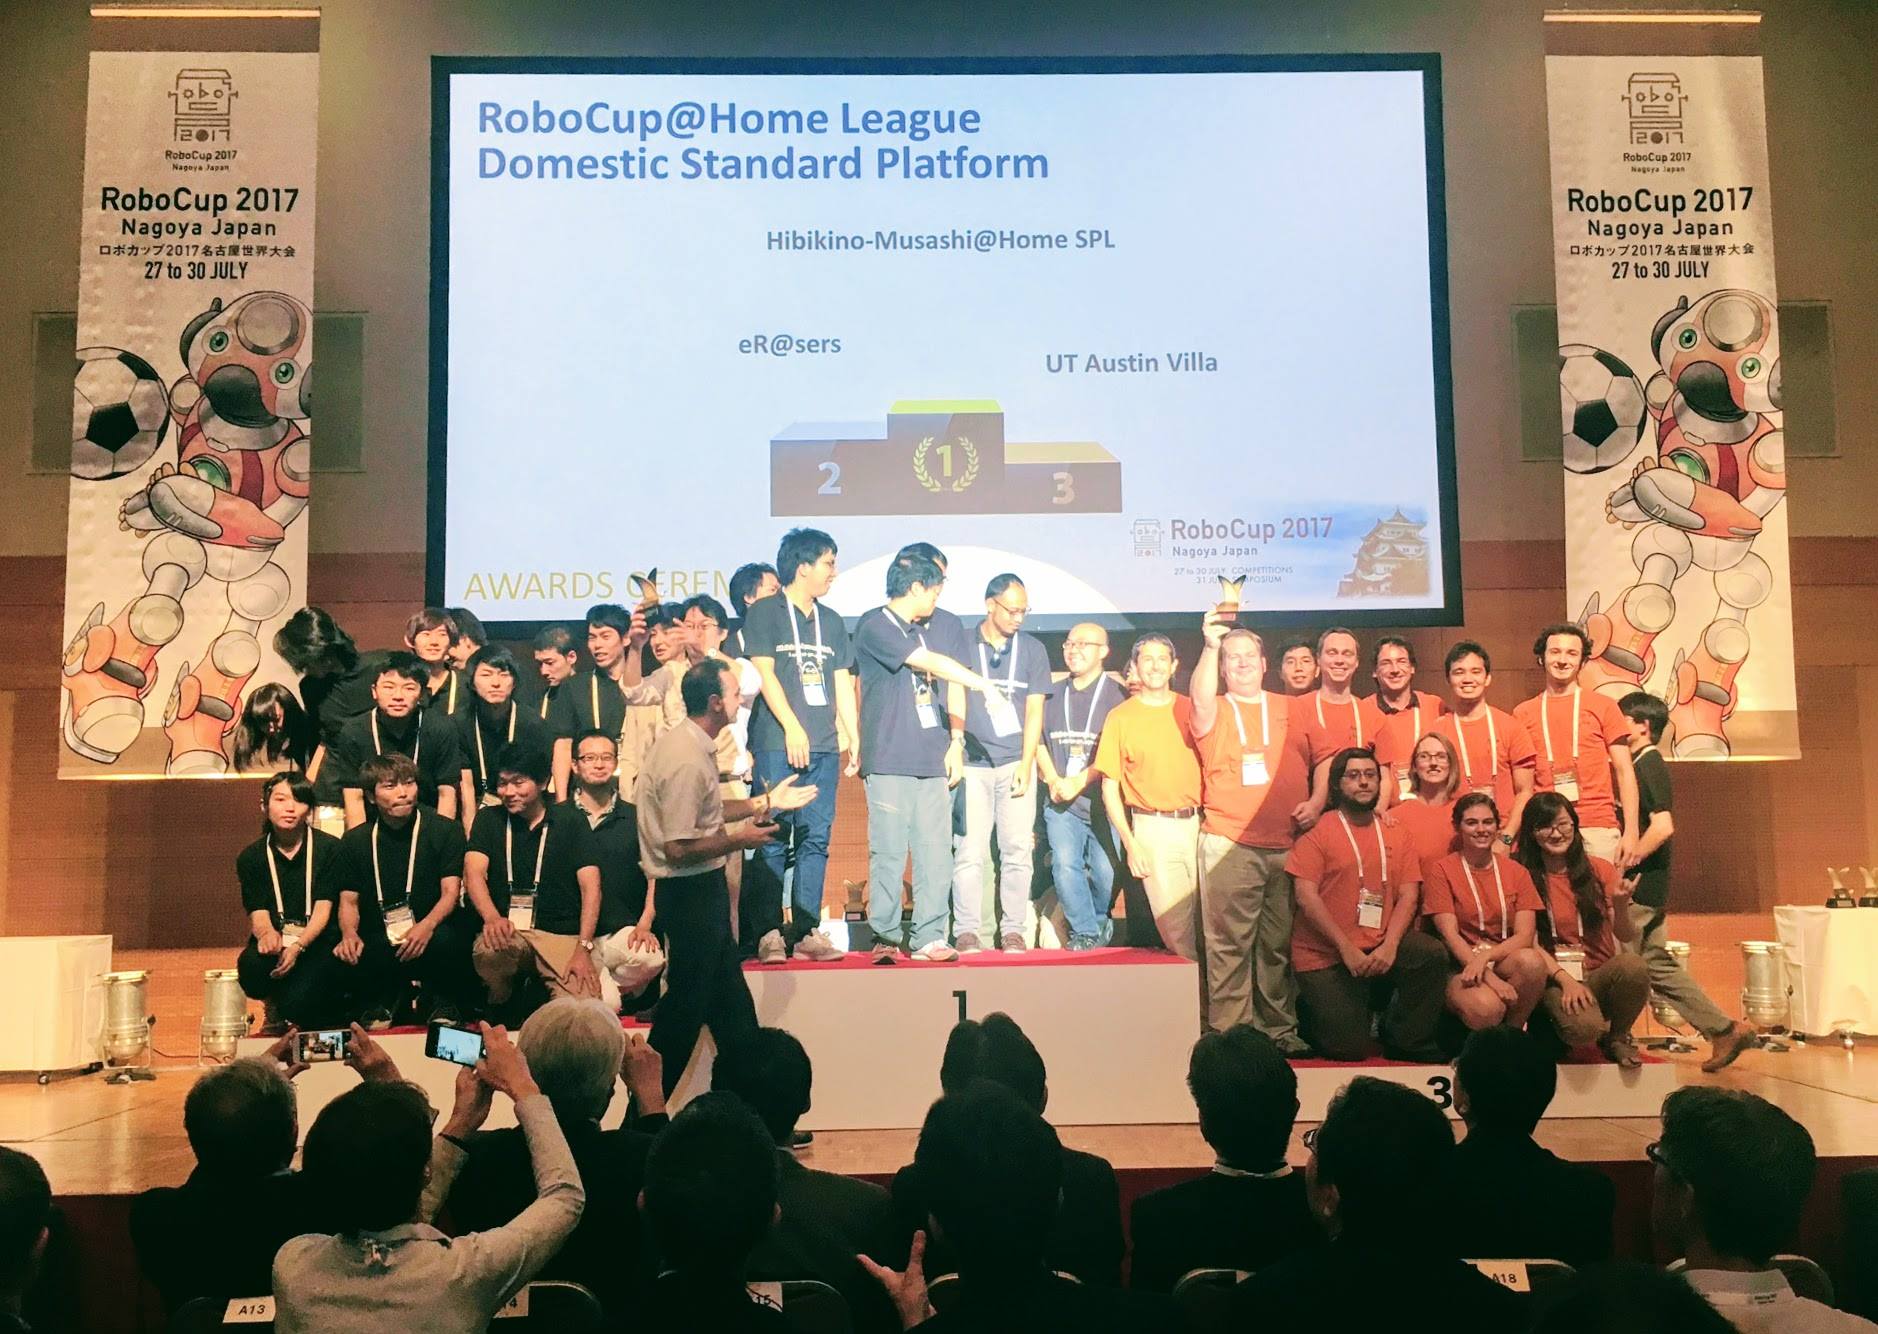
Receiving our third place trophy at RoboCup 2017 in Nagoya, Japan
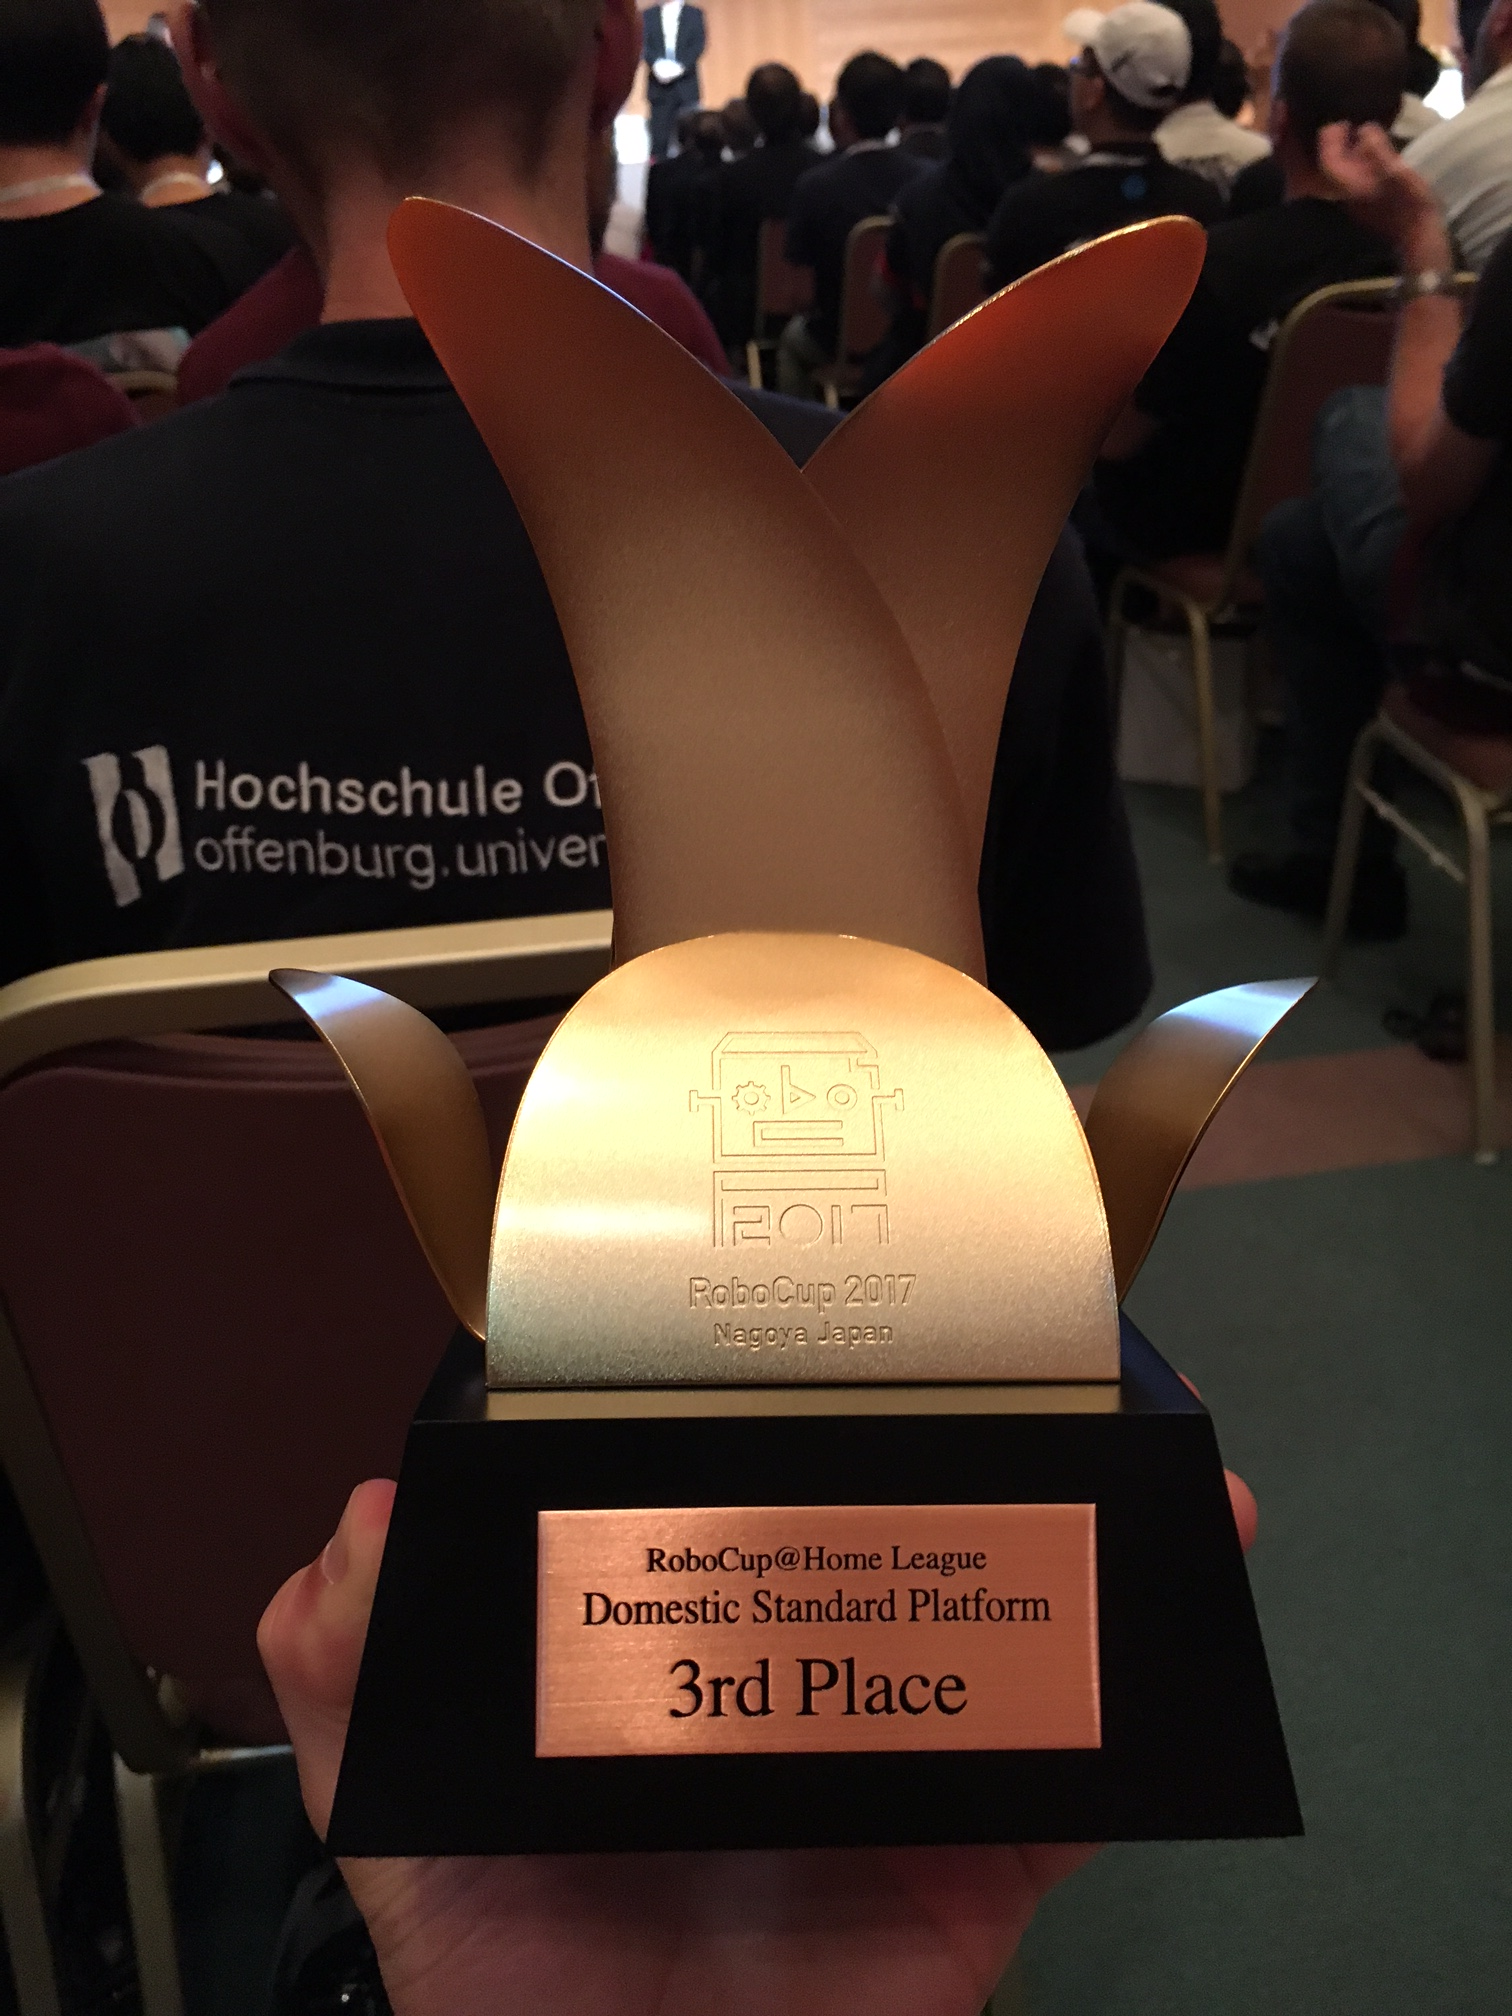
Our third place trophy from RoboCup 2017
The Nagoya crew at RoboCup 2017
Segway in Robocup @Home 2007 Final